Research
Publications
Papers, code, and current manuscripts.
First-authored
Selected work
2026 · Conference paper
Continuous-time optimal control of neural ODEs via Bayesian inference
Neural ODEs: neural ordinary differential equations.
Ali Vaziri, Huazhen Fang · Institute of Electrical and Electronics Engineers (IEEE) Conference on Decision and Control (CDC)
Accepted
2026 · Journal article
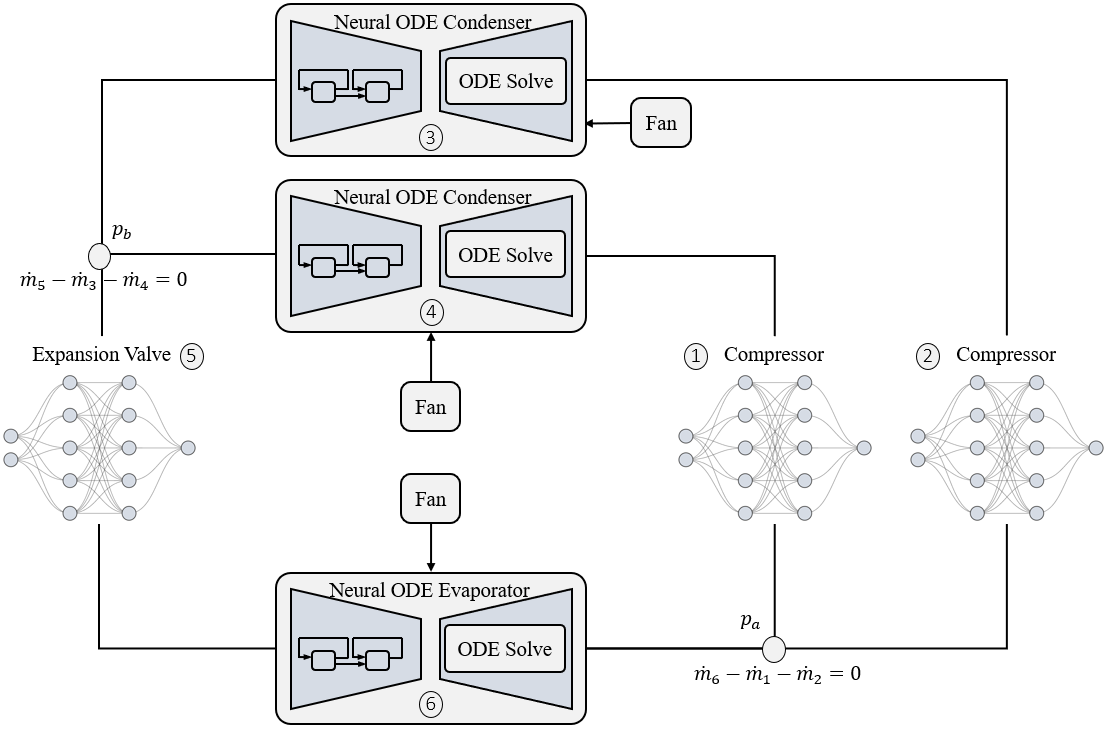
Modular deep learning framework for vapor-compression HVAC systems: scalable, efficient, and physically consistent modeling
HVAC: heating, ventilation, and air conditioning.
Ali Vaziri, Hongtao Qiao, Christopher R. Laughman, Huazhen Fang · Applied Thermal Engineering
2025 · Conference paper
Optimal inferential control of convolutional Neural networks
Ali Vaziri, Huazhen Fang · American Control Conference (ACC) · Best student paper nominee
2025 · Conference paper
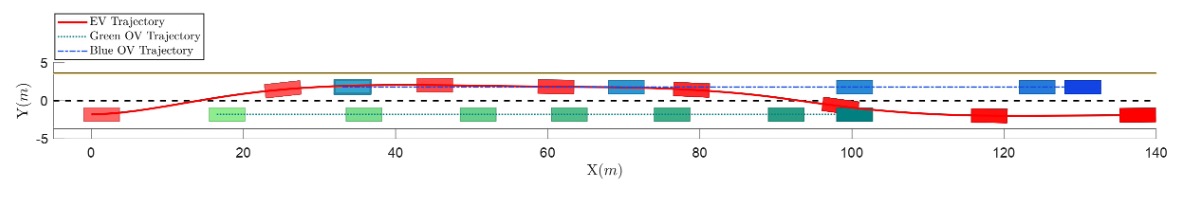
Bayesian inferential motion planning using heavy-tailed distributions
Ali Vaziri, Iman Askari, Huazhen Fang · American Control Conference (ACC)
Co-authored
Peer reviewed
2025 · Journal article
Model predictive inferential control of neural state-space models for autonomous vehicle motion planning
Iman Askari, Ali Vaziri, Xuemin Tu, Shen Zeng, Huazhen Fang · IEEE Transactions on Robotics
Current manuscripts
In preparation
Manuscript
Optimal inferential control of machine learning models
Ali Vaziri, et al.
In preparation
Manuscript
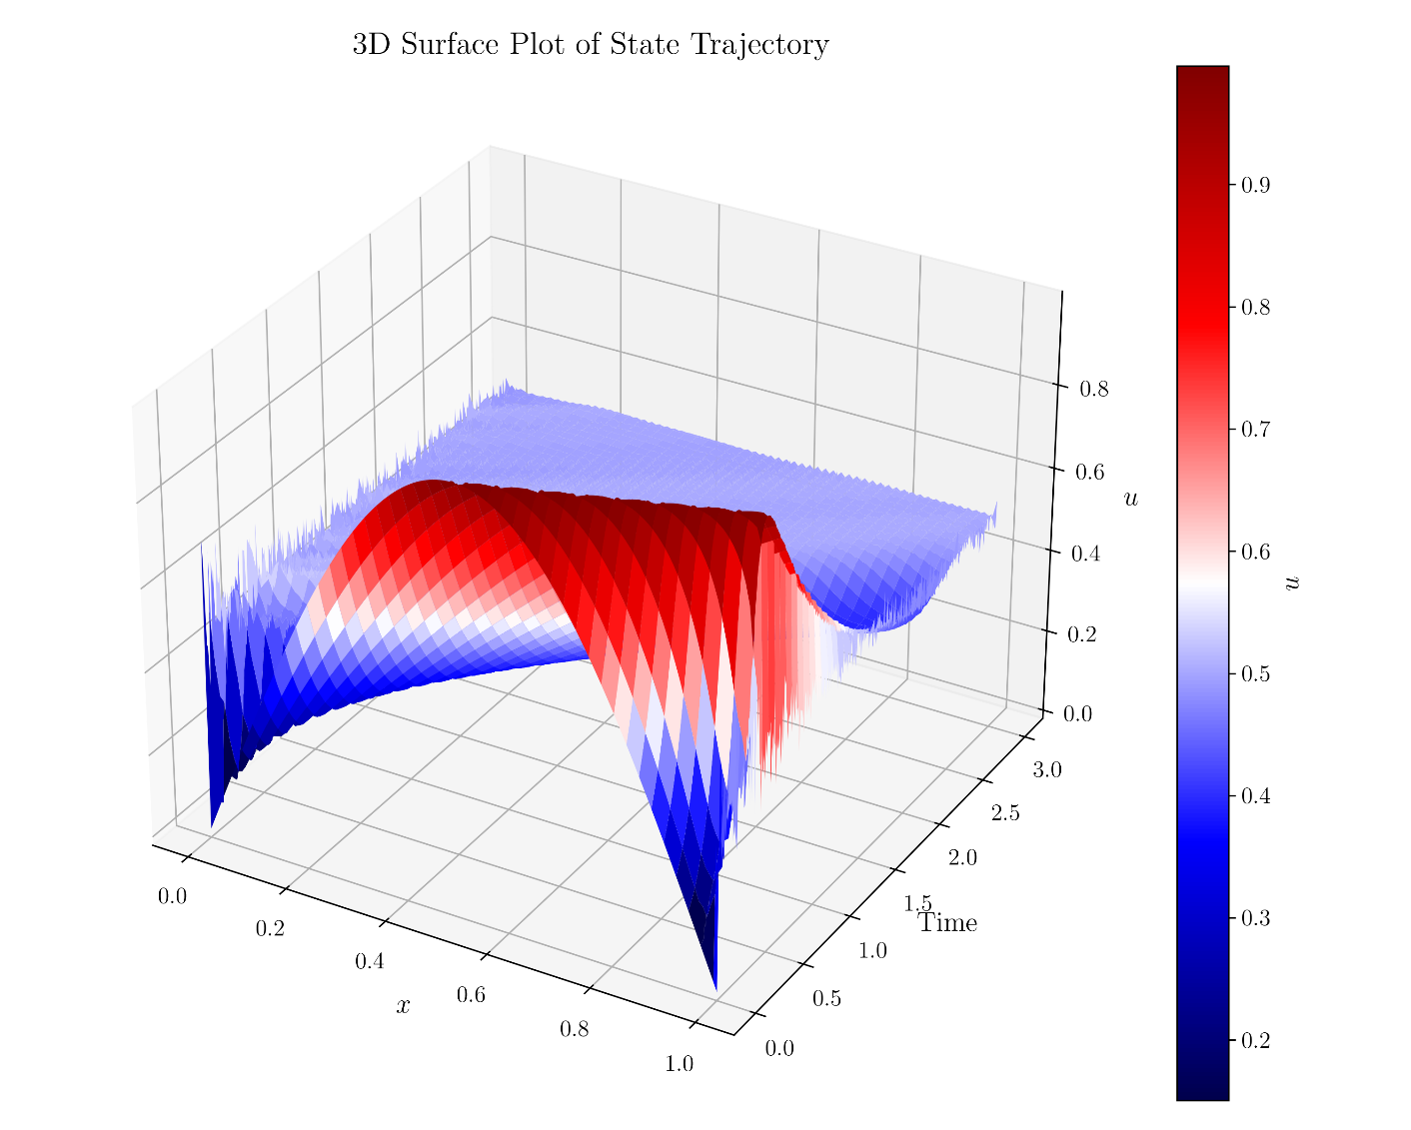
Robust GPU-enabled framework for optimal boundary and distributed control of PDEs
GPU: graphics processing unit. PDEs: partial differential equations.
Ali Vaziri, et al.
In preparation